Marketing site
RoboViewer Landing
A scroll-driven marketing site for RoboViewer. The centrepiece is a Universal Robots UR10e, loaded from its real URDF, running a vacuum pick-and-place as you scroll.
- Client
- Orangewood Labs
- Role
- Design & development
- Year
- 2026
- Live
- roboviewer-website.vercel.app
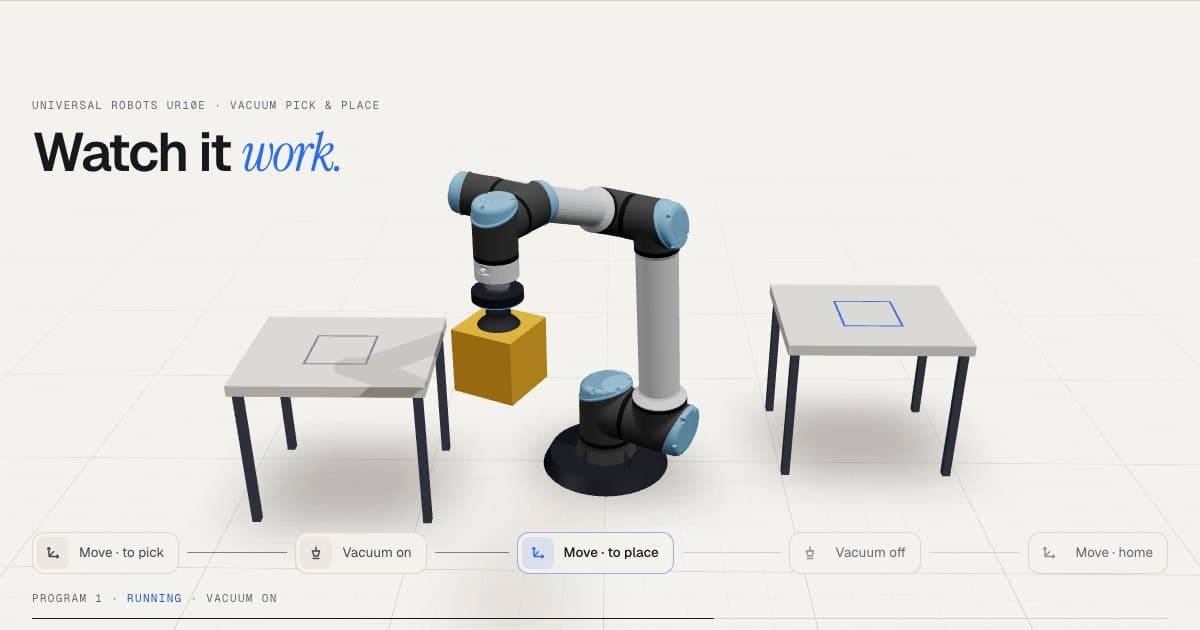
- Real URDF, in the browser
- UR10e
- Robot meshes, compressed
- 9.6 → 1.5 MB
- Drives the robot
- Scroll
01The challenge
Robot simulation software is hard to sell with screenshots. The page had to show what RoboViewer does, a robot running a real program, without asking anyone to install anything.
02The approach
A single page built around a pinned 3D scene: scrolling scrubs one GSAP timeline that drives the UR10e's joints, the vacuum gripper and the camera through a full pick-and-place. The sections that follow walk through building a workcell, visual programming and the robot library, ending in early-access and demo CTAs.
03 What I built
- 01
Scroll-scrubbed robot
One timeline, exactly one unit long, so every tween position is also a scroll fraction. Scrubbing backwards gives the same result as forwards.
- 02
Real robot model
The UR10e URDF from RoboViewer, with joint poses solved offline by IK and meshes converted to meshopt-compressed glTF.
- 03
Renders on demand
The canvas is lazy-loaded, mounts only near the viewport and draws a frame only when the timeline moves.
- 04
Graceful fallbacks
Smooth scrolling is desktop only, reduced motion gets a still frame, and browsers without WebGL get a one-line notice.
04 Stack